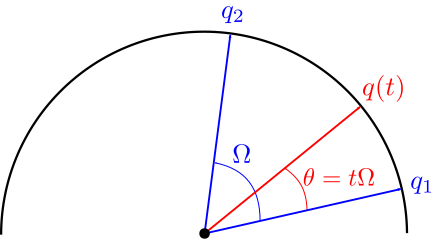
Spherical Linear interpolation (
SLERP)
- - Consider two rotations with corresponding quaternion \(q_1\), \(q_2\).
- - The spherical linear interpolated quaternion at parameter \(t\in[0,1]\) is
-
- \(\displaystyle q(t) = \frac{\sin ((1-t)\Omega)}{\sin(\Omega)} q_1 + \frac{\sin (t\Omega)}{\sin(\Omega)} q_2 \;\;\;\) with \(\cos(\Omega)=q_1
\cdot q_2\)
- (+) Follows a shortest path (great circle on 4D sphere)
- (+) Constant angular speed
- (-) Cannot be generalized to more general curves.
-
- Cannot interpolates between more than two quaternions