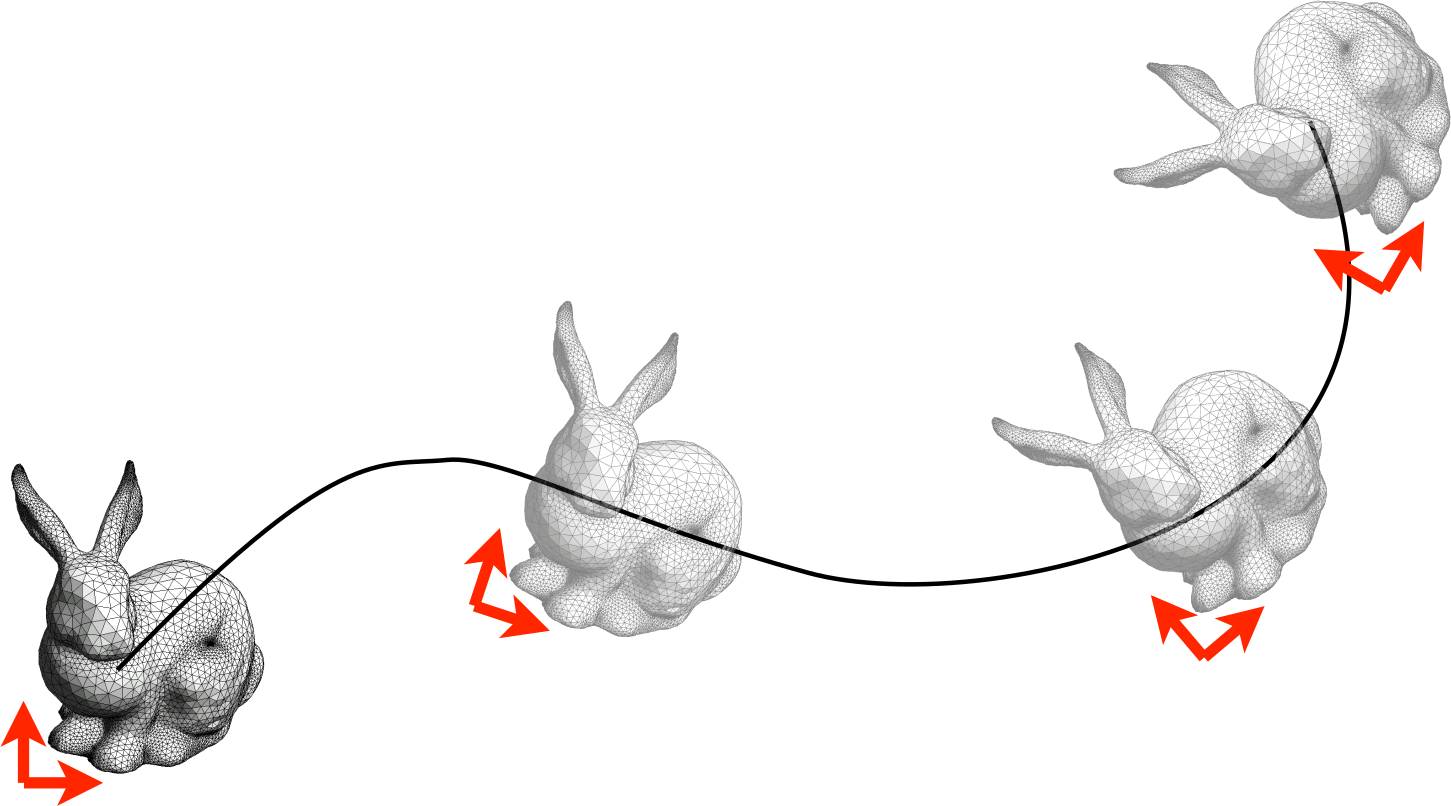
- \(\Rightarrow\) Need to interpolate both, usually handled separately.
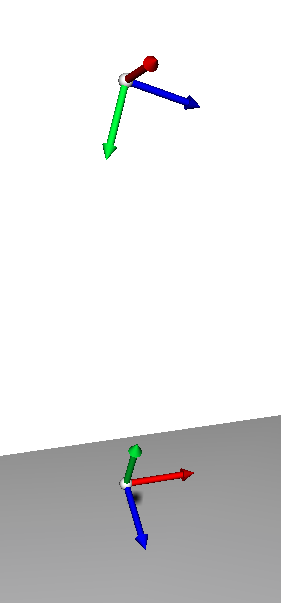
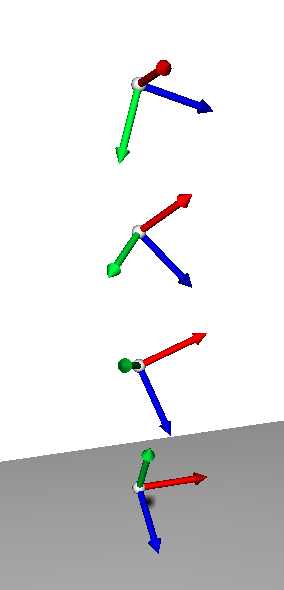
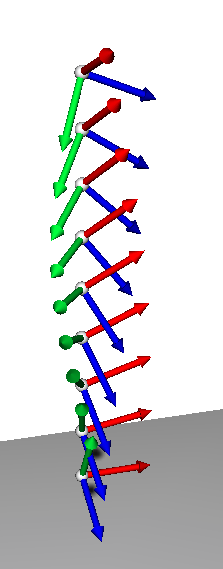
Given two key-positions \((p_1,r_1)\) and \((p_2,r_2)\) in-betweens computed at time \(t\in[0,1]\) as
- - Linear interpolation of positions \(p(t) = (1-t)\, p_1 + t\, p_2\)
- - Interpolate rotation with SLERP on quaternions
-
- - Convert \((r_1,r_2) \to (q_1,q_2)\)
- - Compute \(q(t) = SLERP(q_1,q_2,t)\)
- - Convert back \(q(t) \to r(t)\)