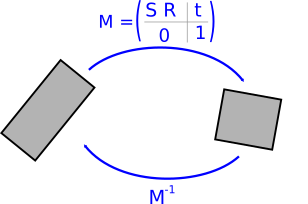
Q. Consider the affine transform \(M\) parameterized by a scaling \(s\), a rotation \(R\), and a translation \(t\).
> Express the inverse matrix \(M^{-1}\) with respect to \(s\), \(R\) and \(t\)
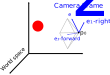
Q. Consider a camera described by its frame:
- a position \(p_0\)
- an orientation expressed by the three unit vectors \((e_1,e_2,e_3)\) corresponding respectivelly to the right, up, and forward
direction.
> Express the view matrix that should be applied in the shader, i.e. the matrix to apply to each 3D vertex position in order to
model the effect of the camera position and orientation (3D world space \(\to\) view space).