Multiple collisions
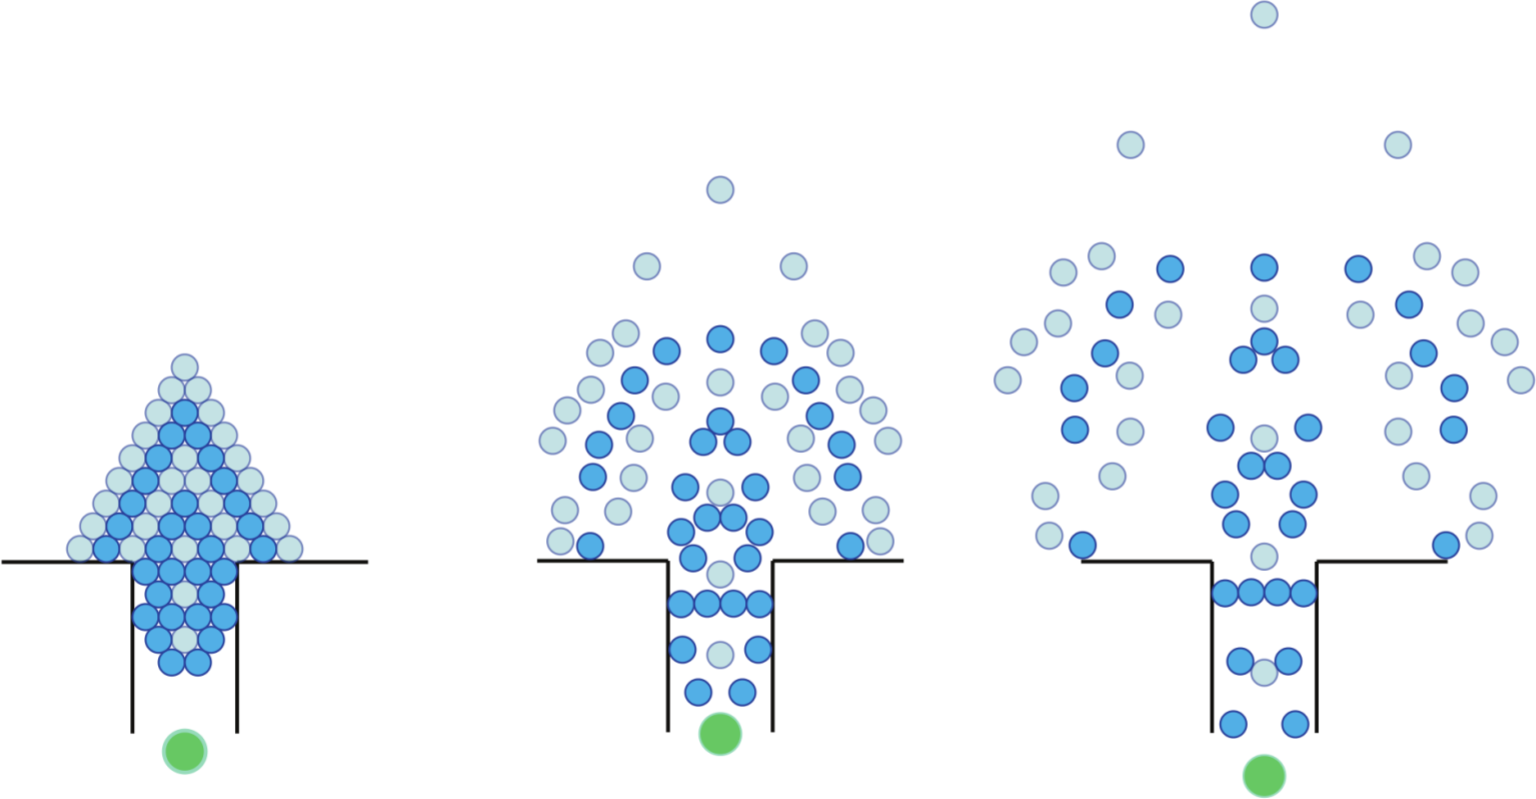
- Pairwise collisions \(\Rightarrow\) no global collision free state
-
- - Correcting one collision may induce new collisions.
- - Order of correction does matter
- Reducing time-step help, Iterating over mutliple pass help
- But correct solution in all cases is complex \(\rightarrow\) global approach
-
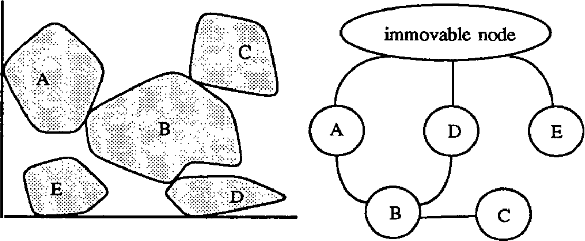
- - Precompute contact graph
-
-
- explicit shock propagation management
-
- - Global constraint-based method
-
-
- Impulse: \(n_i \cdot (v_i-v_j) \geq 0\)
- Momentum preservation: \(m_i v_i-m_j v_j=0\)
- Energy preservation/dissipation
- \(\Rightarrow\) Linear Complementarity Program, Gauss Seidel, etc.