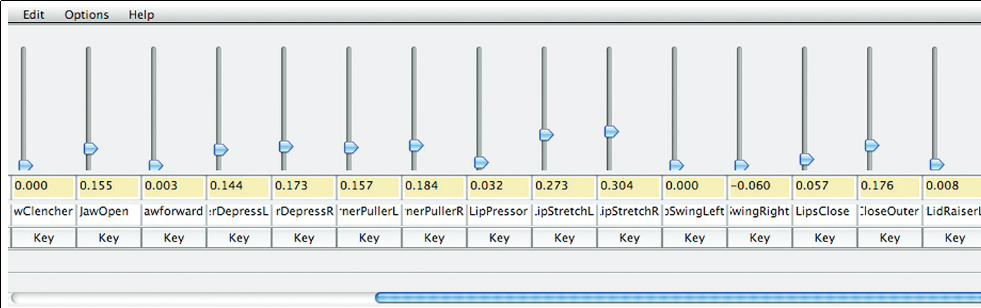
Blend shapes
- Represent deformation as a difference of coordinates with respect to neutral pose
- - Per-vertex formulation
-
- \(\displaystyle p_i(t)=b^0_i+\sum_{k}^{N_{\scriptsize{poses}}} \omega_k(t)\, (\underbrace{b_{ki}-b^0_i}_{d_{ki}})\)
- - Matrix formulation \({\bf p}(t)={\bf b^0}+\mathrm{D}\,\mathbf{\omega}(t)\)
- Can add/substract local expressions (even extrapolate)
-
- as long as they are not interfering/redundant
- Allows expression transfert (keep same \(\mathrm{D}\) for different faces \(b^0\)).
-
- same connectivity required
- Note:
-
- - \(D\) is not an orthogonal matrix (non unique combination, redundancies) \(\Rightarrow\) decomposition PCA, etc.
- - How to directly manipulate blend shapes