Controlers
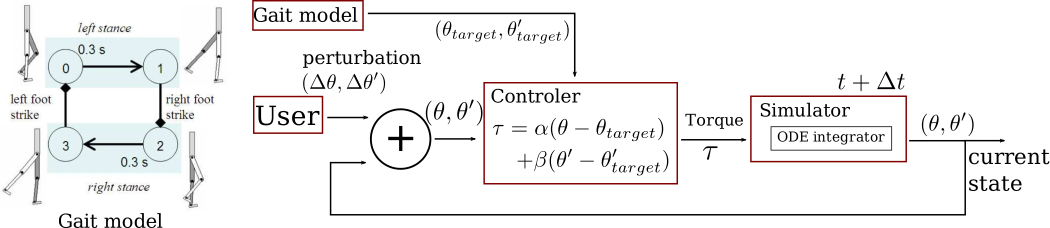
- Mix between predefined motions and physics \(\rightarrow\) allow user perturbations
-
- 1 - Define target (\(\theta_{target}(t),\theta'_{target}(t)\))
-
- pre-defined finite state machine (Gait model)
- 2 - Add user perturbation to the current state
- 3 - Use proportional derivative controlers to compute joint torque \(\tau\)
- 4 - Integrate torque using rigid body simulator
- 5 - Iterate