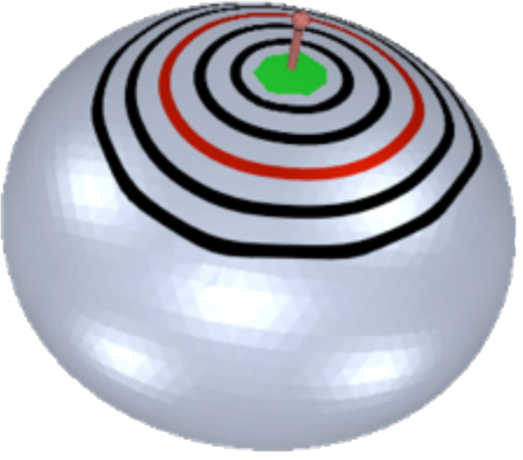
Spatial / Surface based deformation
- Consider a shape defined as \((p_i)_{i\in[0,N-1]}\) positions
Spatial/volume deformation
- Define spatial deformation \(\forall p\in\mathbb{R}^3\,,\;\;f: p \to f(p)\)
-
- Apply \(f\) to every positions
- \(\forall i\in[0,N-1]\,,\; q_i = f(p_i)\)
- (+) Independant from shape representation
-
- Point sets, Surface, Volume.
- (-) Indirect control
-
- Spatial deformation \(\to\) shape deformation
- (-) Deformation fully defined by spatial position
Surface-based
- Compute deformation on surface only
-
- Deformation is defined at \(p_i\)
- But not at arbitrary position in space
-
-
- ex. \(q_i = p_i+n_i\), \(\;\;n_i\):surface normal at position \(p_i\)
- (+) Can integrate/preserve surface properties (neighborood, curvature, etc.)
- (-) Sensible to surface representation & connectivity.