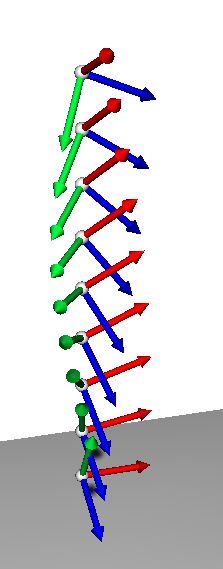
Interpolating rotation
Do not use componentwise-interpolation on rotation matrix
- \(\Rightarrow\) interpolate in quaternion space
Can use either:
- - SLERP - Spherical Linear Interpolation
-
- \(\displaystyle q(t) = \frac{\sin((1-t)\Omega)}{\sin(\Omega)}\,q_1 + \frac{\sin(t\Omega)}{\sin(\Omega)}\,q_2,\;\;\;\) with \(\cos(\Omega)=q_1
\cdot q_2\)
-
- Between two unit quaternions \(q_1,q_2\)
- - LERP - Linear Interpolation
-
- \(\displaystyle q(t) = \frac{\sum_j \alpha_j \, q_j}{\|\sum_j \, \alpha_j q_j\|}\)
-
- When blending multiple quaternions \(q_j\) with weights \(\alpha_j\)
Rem.
- When interpolating b/w rotations and positions:
-
- Use quaternion with rotation, componentwise-interpolation on position