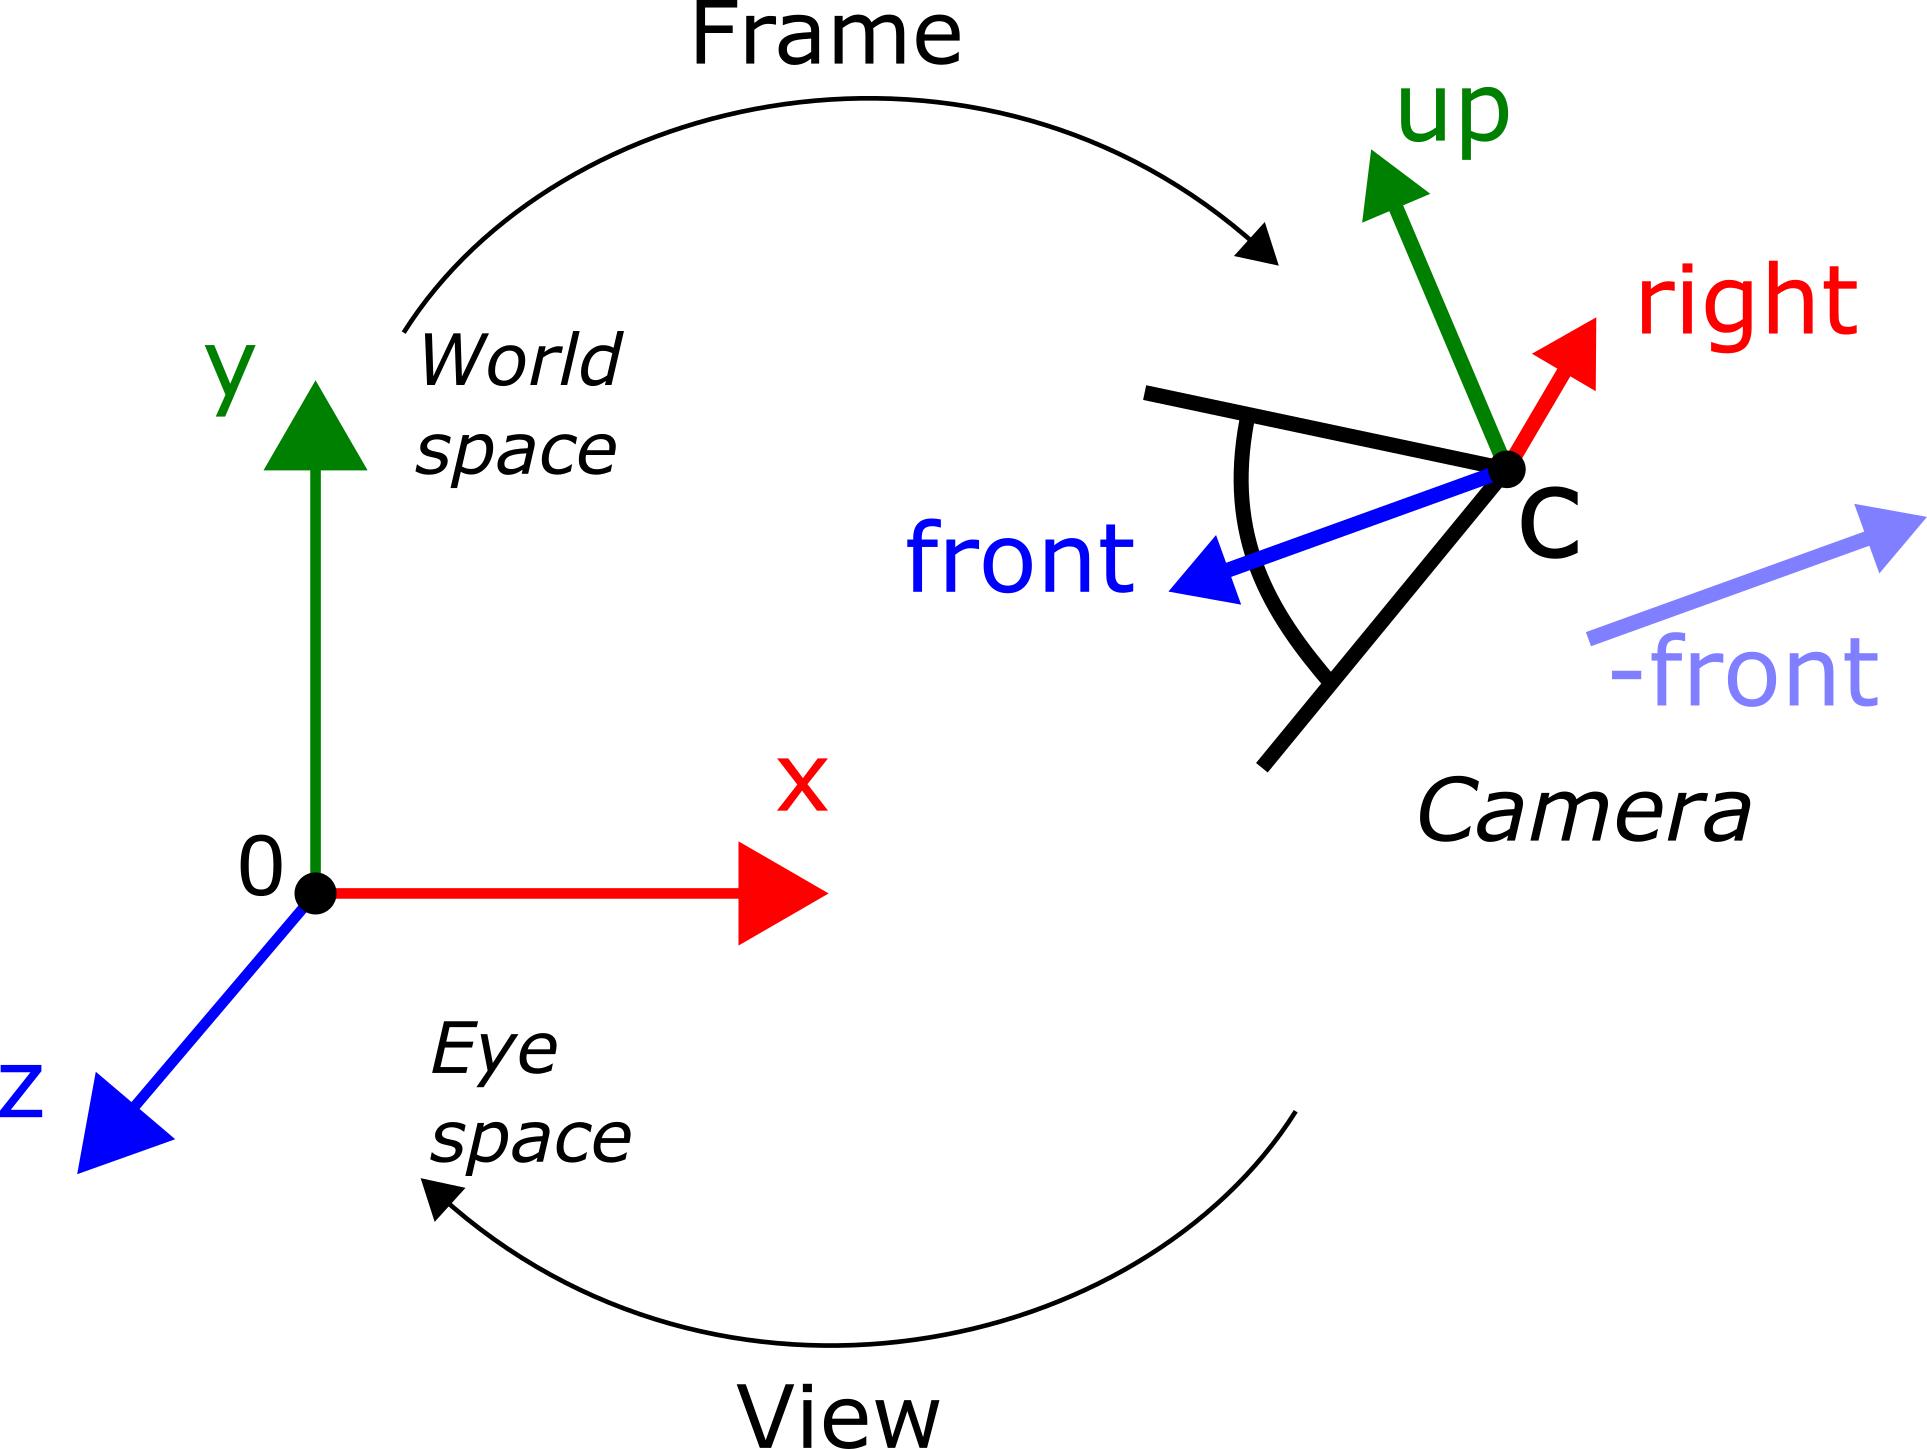
View matrix: inverse of the Frame matrix
- Transforms the camera vectors into the unit coordinates
- \(View\times right = (1,0,0,0)\)
- \(View\times up = (0,1,0,0)\)
- \(View\times -front = (0,0,1,0)\)
- \(View\times c = (0,0,0,1)\)
- Orientation \(O\) can be read on the rows
-
- View=\(\left(\begin{array}{cccc} ( \cdots & right & \cdots ) & | \\ ( \dots & up & \cdots ) & - O^{T}\,c \\ ( \cdots & -front & \cdots ) & |
\\ 0 & 0 & 0 & 1 \end{array}\right)\)