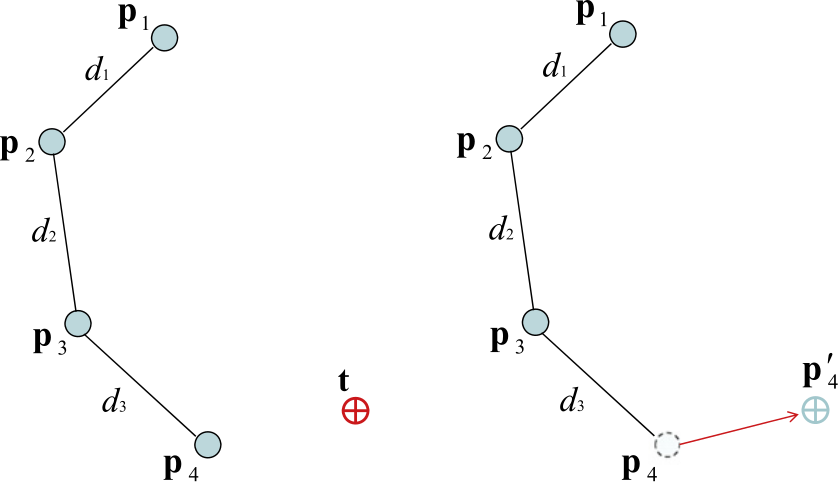
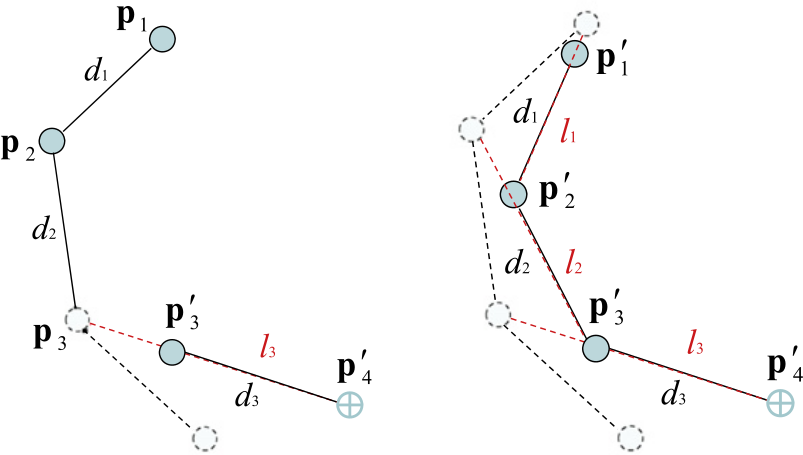
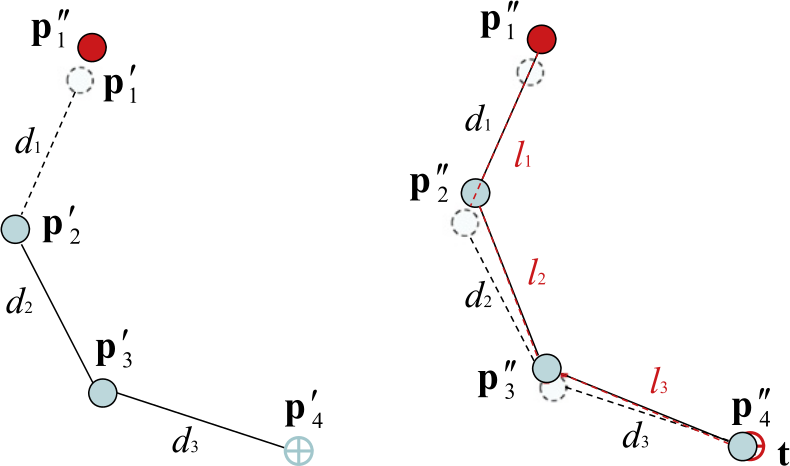
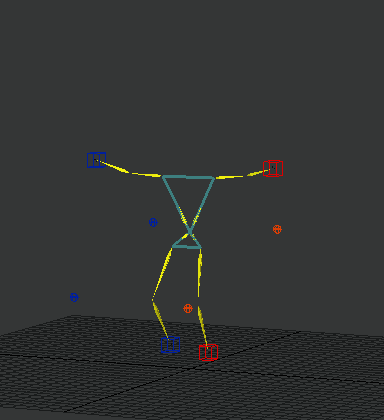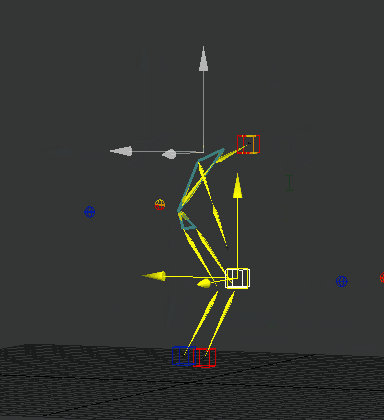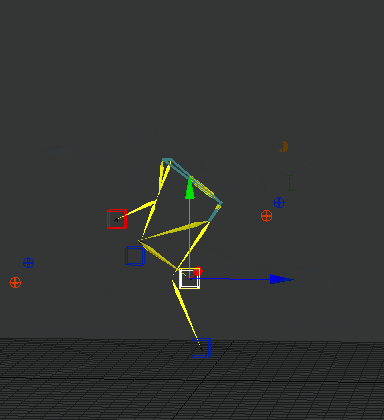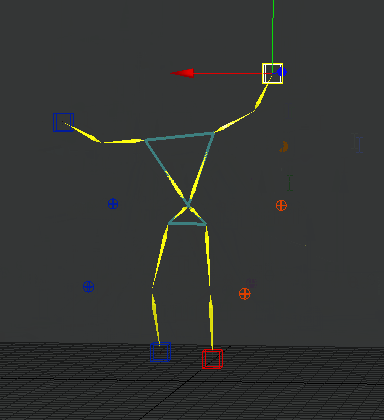- Iterate between
-
- - Forward direction: Match the end-effector target
-
- propagate changes toward previous position to match bones' length.
- - Backward direction: Match the starting position
-
- propagate changes toward following positions to match bones' length.
A fast iterative solver for the Inverse Kinematics problem. A. Aristidou. Graphical Models 2011.