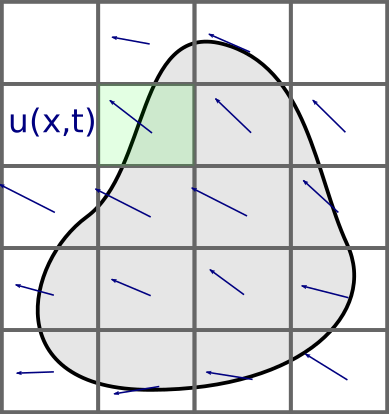
- In Euler formulation quantities are expressed at fixed position in 3D space.
- Deformation described by velocity \(u(p,t)\) at a given 3D fixed point \(p=(x,y,z)\) at time \(t\).
-
- - Do not require anymore a reference shape
- - Usefull for heavily deforming shapes (ex. fluids, gaz).
- - Change of speed during \(\mathrm{d}t\)
-
- \(\displaystyle \frac{\mathrm{d}u}{\mathrm{d}t}(p,t)=\frac{\partial u}{\partial t}+\sum_i \frac{\partial u}{\partial
p_i}\,\underbrace{\frac{\mathrm{d}p_i}{\mathrm{d}t}}_{u_i} = \frac{\partial u}{\partial t}+ (u\cdot \nabla) u\)
- Called material derivative.
- - Similarily to Lagrangian derivation:
-
- - Strain-rate tensor \(\epsilon\) (rate of change of deformation in a neighborhood of a point)
-
- expressed with respect to \(u\): \(\epsilon=\frac{1}{2}\left(\nabla u+\nabla u^T\right)\)
- - Stress-rate tensor \(\sigma\) (rate of change of direction force per area in a neighborhood of a point).