4
/37
Rigid skinning
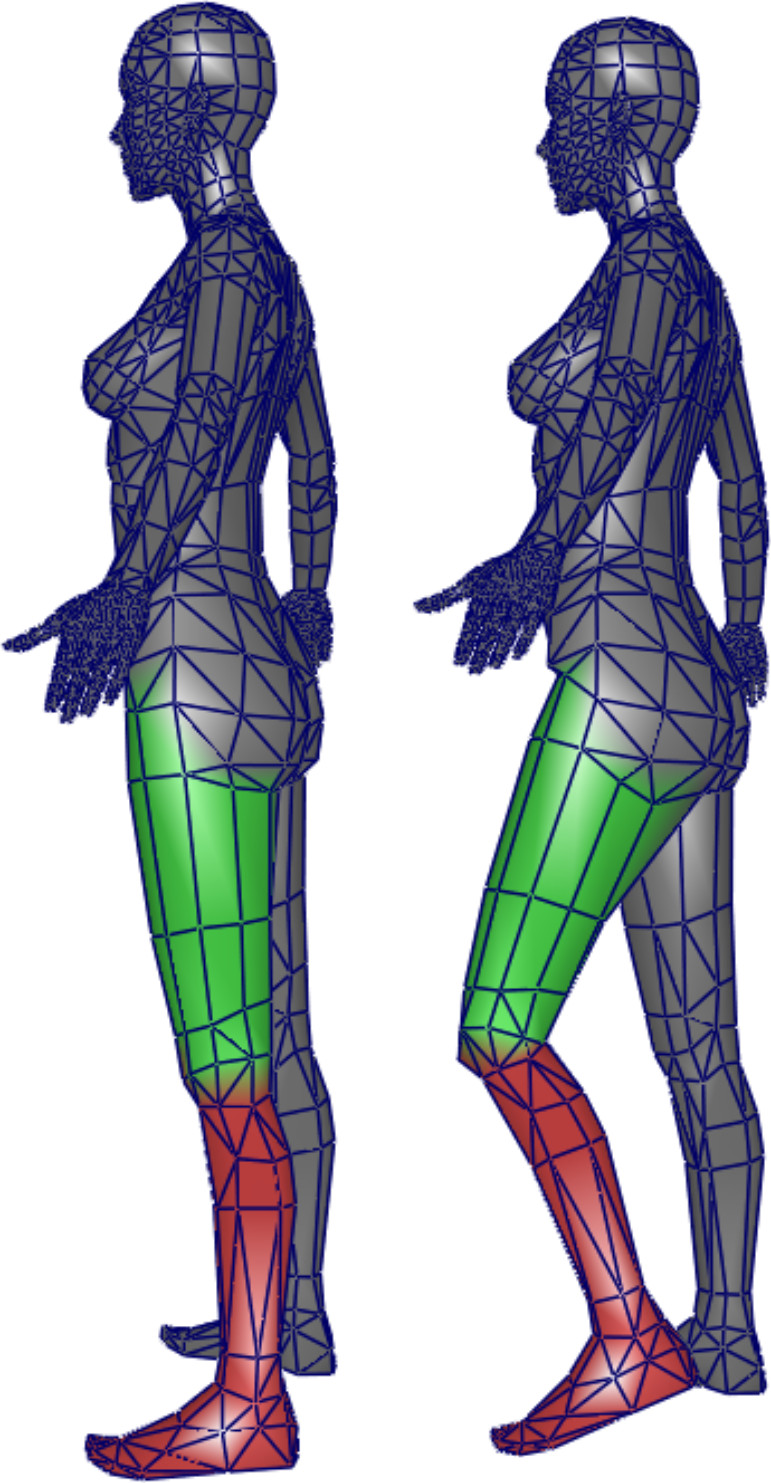
Attach rigidly subset of vertices to specific bones, described by its root joint/frame.
Vertices are following rigid deformation of their associated frame.
Deformation formulation
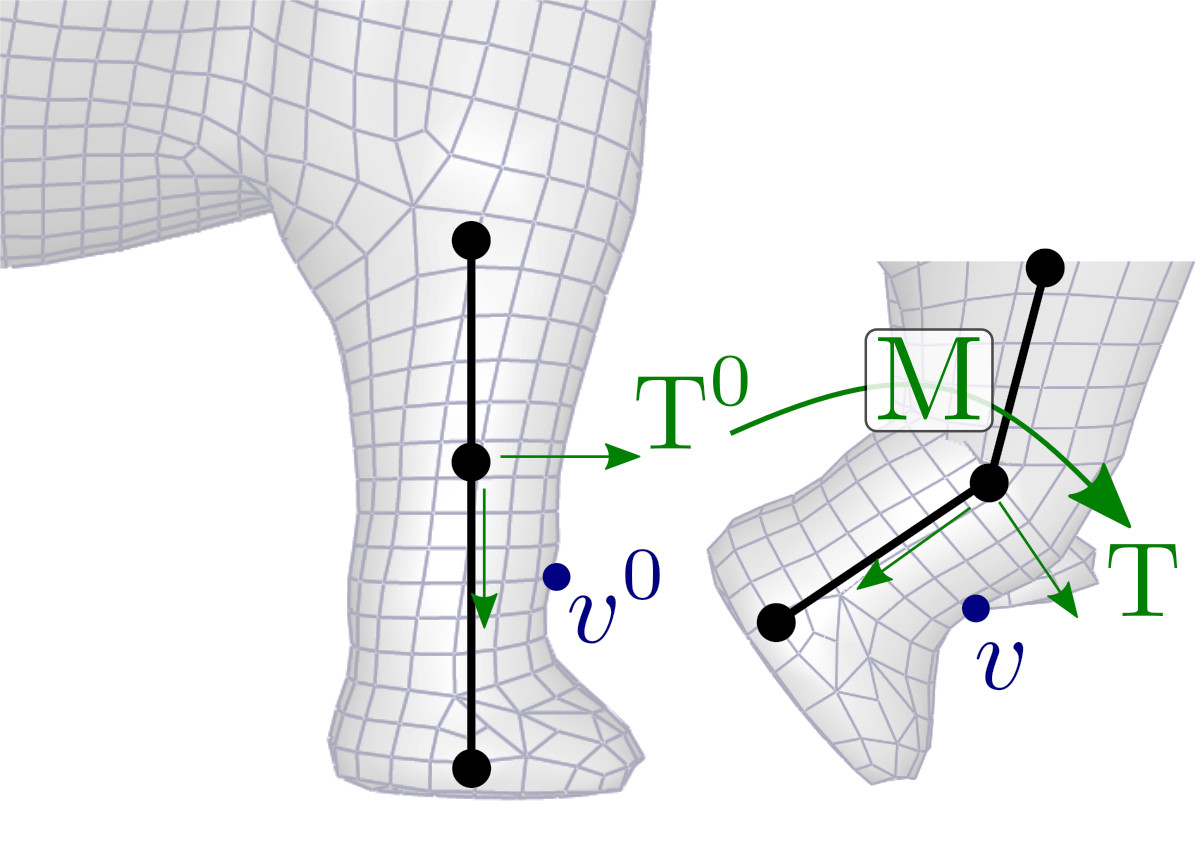
Consider, at rest pose/initial state
- A frame \(\mathrm{T}^0\)
- A vertex \(v^0\) attached to this frame
After deformation
- New frame \(\mathrm{T}\)
- New vertex position \(v\)
Question:
What are the new coordinates \(v\) w/r \(\mathrm{T}\), \(\mathrm{T}^0\), \(v^0\) ?
\(v^0\) and \(v\) have similar local coordinates w/r to \(\mathrm{T}^0\) and \(\mathrm{T}\)
\(\Rightarrow \mathrm{T}^{-1} v = (\mathrm{T}^0)^{-1} v_0\)
\(\Rightarrow v = \mathrm{T}\;(\mathrm{T}^0)^{-1} v_0 = \mathrm{M}\,v_0\)