camera_orbit
Camera orbiting around a center of rotation.
Derives from: camera_generic_base
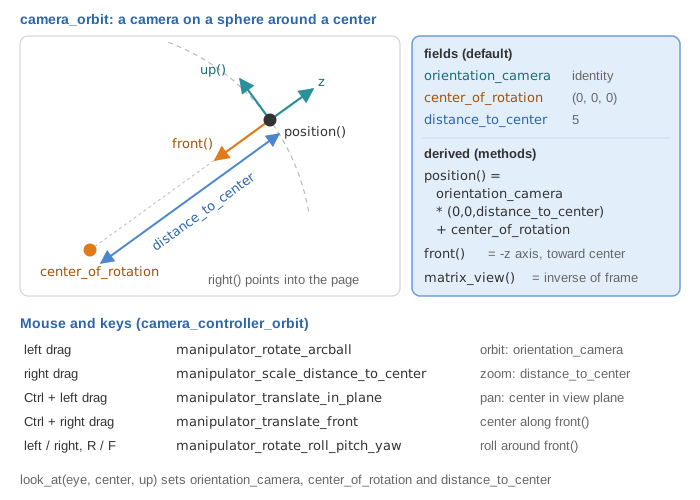
Fields and methods
Members of the struct camera_orbit. Most of what you do with a CGP type goes through the free functions listed below.
Fields
rotation_transform orientation_camera | Orientation of the camera frame (identity by default, the camera then looks toward -z). |
vec3 center_of_rotation | Point the camera orbits around and looks at, (0,0,0) by default. |
float distance_to_center | Distance between the camera position and center_of_rotation, 5 by default. |
Methods
| Builds an orbit camera with identity orientation, center at the origin and distance_to_center = 5, so that the camera sits at (0,0,5) looking toward -z. src | |
| Returns the camera position, center_of_rotation + orientation_camera * (0,0,distance_to_center). src | |
| Returns orientation_camera. src | |
| Rotates the camera around center_of_rotation from the mouse displacement p0 -> p1 given in relative screen coordinates [-1,1] (arcball/trackball rotation; no effect if the displacement is below 1e-4). src | |
| Applies an incremental rotation, expressed in the current camera frame, of angles roll (around the view direction), pitch (around the right axis) and yaw (around the up axis), in radians, around center_of_rotation. src | |
| Multiplies distance_to_center by (1 + magnitude), clamped to at least 0.01; the center is unchanged. src | |
| Translates center_of_rotation (and thus the camera) by tr.x * right() + tr.y * up(). src | |
| Translates center_of_rotation (and thus the camera) by magnitude * front(). src | |
| Places the camera at eye looking toward center with the given up vector, setting center_of_rotation = center and distance_to_center = norm(eye-center). src |
Inherited from camera_generic_base (6 members)
Methods
| Returns the camera frame built from orientation() and position(). src | |
| Returns the 4x4 view matrix (world to camera), the inverse of the camera frame matrix. src | |
| Returns the 4x4 matrix of the camera frame (camera to world), the inverse of matrix_view(). src | |
| Returns the viewing direction, the opposite of the third column (local z axis) of orientation(). src | |
| Returns the up direction of the camera, the second column (local y axis) of orientation(). src | |
| Returns the right direction of the camera, the first column (local x axis) of orientation(). src |
Functions taking a camera_orbit
Compute 3
Documented on another page
picking_mesh_vertex_as_sphereCasts the camera ray through the screen position and returns the closest vertex whose sphere of radius picking_distance it hits, with the hit point, the vertex normal and the vertex index (active is false if none).onvec2picking_plane_orthogonal_to_cameraIntersects the camera ray through the screen position (relative coordinates) with the plane through plane_position orthogonal to the front direction of the camera.onvec2picking_spheresCast a ray through a screen position (normalized device coordinates) and return the closest hit among spheres of common radius, with its index, position and normal.onvec2
Functions returning a camera_orbit
None.
Operators
None.