Rotations
- 3D rotations have 3 dof, No unique representation
Matrix
- \(R=\left(\begin{array}{ccc}R_{xx} & R_{xy} & R_{xz} \\ R_{yx} & R_{yy} & R_{yz} \\ R_{zx} & R_{zy} & R_{zz} \end{array}\right)\)
- \(R^T\,R=\mathrm{I}\)
- \(\mathrm{det}(R)=1\)
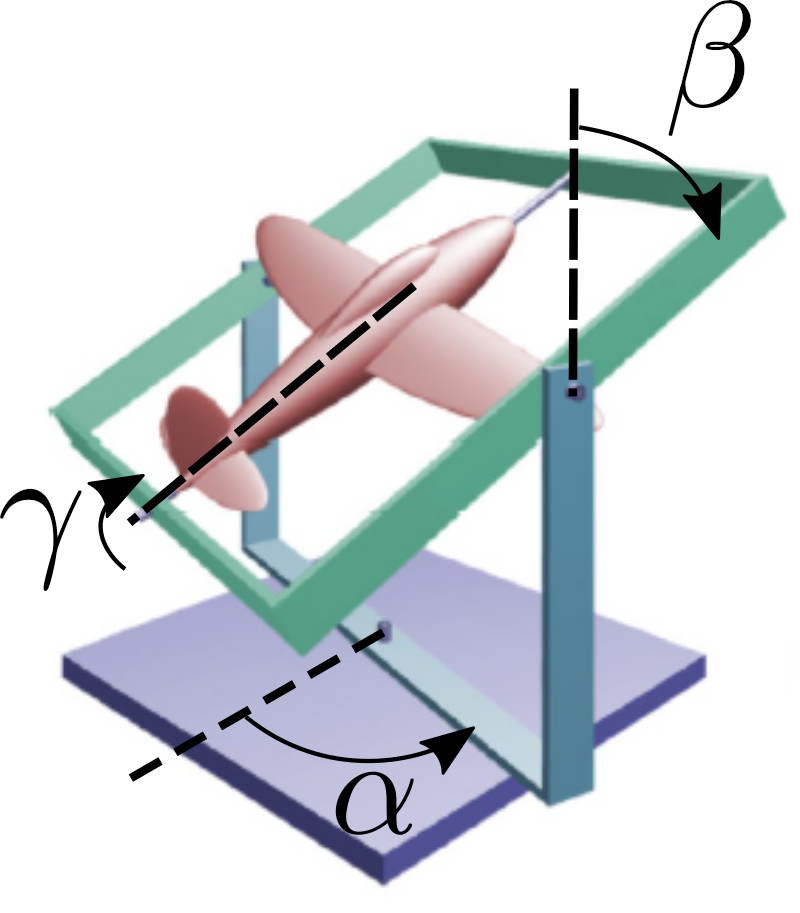
Euler Angles
- 3 angles: \((\alpha,\beta,\gamma)\)
- Composition of rotation around basic axes
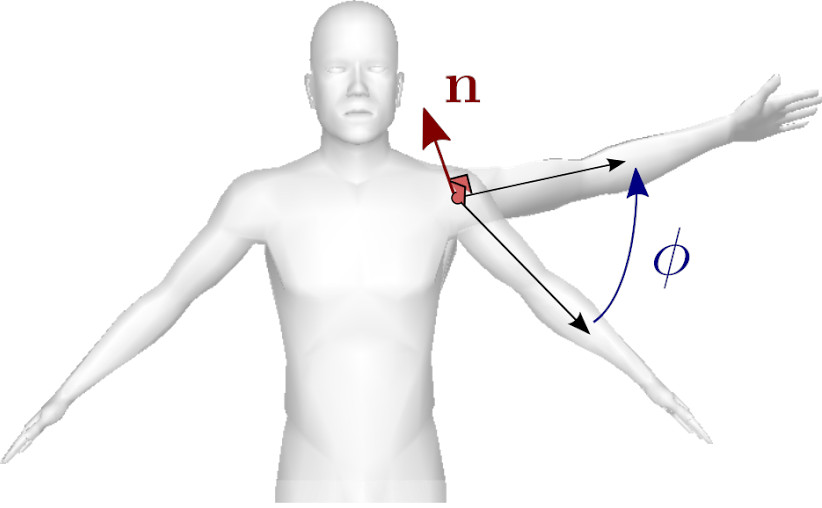
Quaternion
- \(q=(x,y,z,w)\)
- \(=\left({\bf n}\,\sin\left(\frac{\theta}{2}\right),\cos\left(\frac{\theta}{2}\right)\right)\)