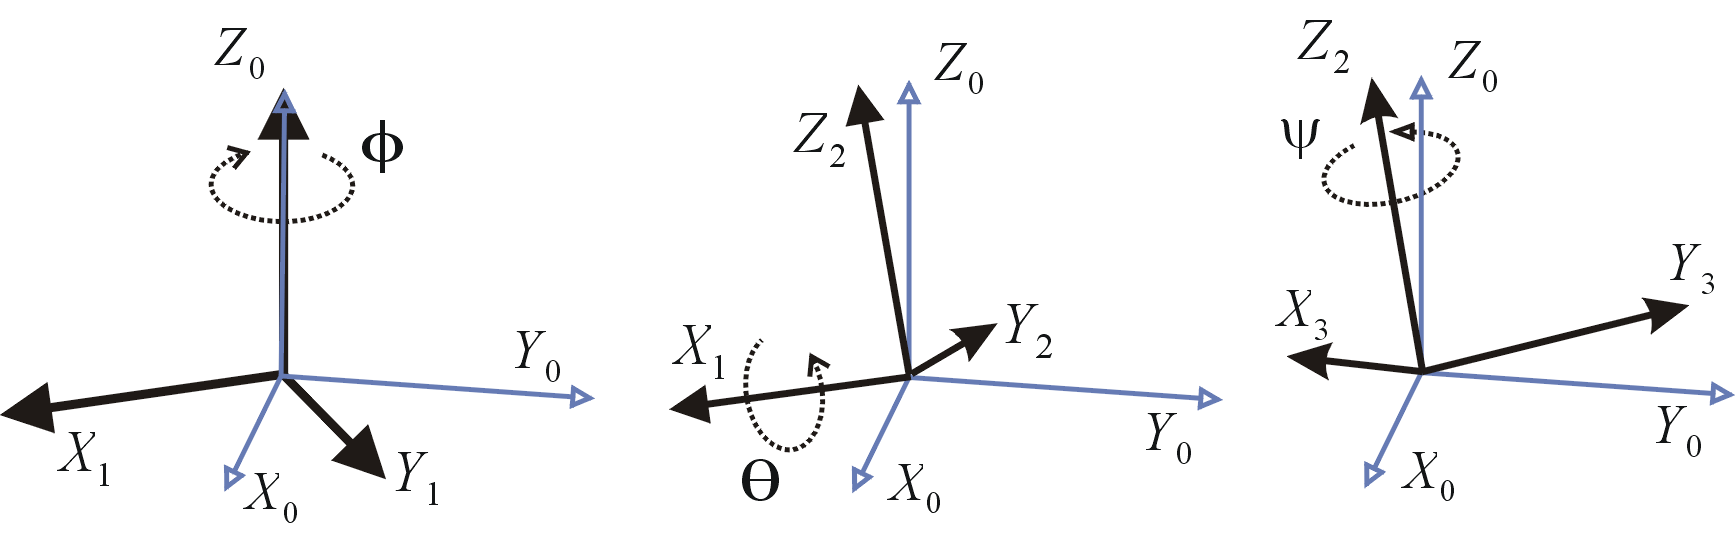
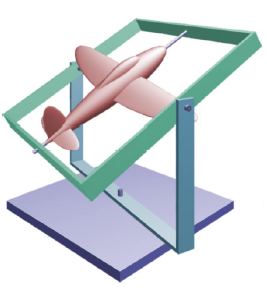
Rotation: Focus Euler angles
- Three consecutive rotations along fixed axis along \((x,y,z)\) coordinates.
- Can use basic rotation matrices composition
- \(R_x=\left(\begin{array}{ccc}1 & 0 & 0 \\ 0 & \cos(\alpha) & \sin(\alpha) \\ 0 & -\sin \alpha) & \cos(\alpha)\end{array}\right) \;\;\) \(R_y=
\left( \begin{array}{ccc} \cos(\beta) & 0 & \sin(\beta) \\ 0 & 1 & 0 \\ -\sin(\beta) & 0 & \cos(\beta) \end{array} \right) \;\;\) \(R_z= \left(
\begin{array}{ccc} \cos(\gamma) & \sin(\gamma) & 0 \\-\sin(\gamma) & \cos(\gamma) & 0 \\0 & 0 & 1 \end{array} \right) \)
- Multiple Euler angles conventions
-
- - Proper Euler : z-x-z', x-y-x', y-z-y', ...
- - Trait-Bryan : x-y-z, z-y-x, x-z-y, ...
- Take care when exporting/importing/parsing between Softwares
-
- - Combination of rotation around known axis
- - Comprehensive parameters (3 dof)
- - Animators can interact with angular curves
- - Widely used in robotics