mat4
4x4 matrix of floats (affine and projective transforms).
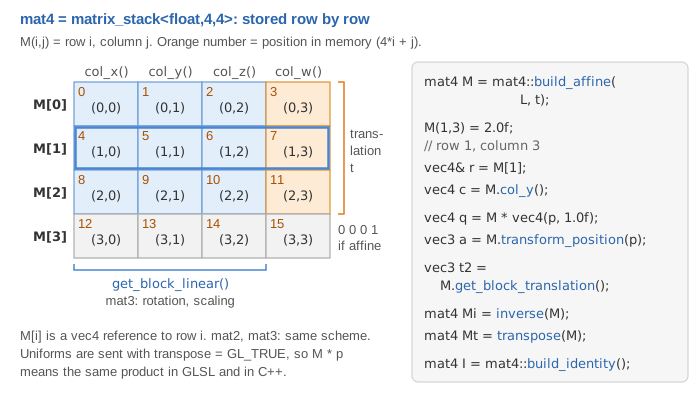
Fields and methods
Members of the struct matrix_stack<float,4,4>. Most of what you do with a CGP type goes through the free functions listed below.
Fields
numarray_stack<numarray_stack<float,4>,4> data | Coefficients stored row by row as 4 rows of 4 floats, contiguous in memory. |
Methods
matrix_stack() | Builds a matrix with all elements set to zero.11 overloads src |
matrix_stack(numarray_stack<numarray_stack<float,4>,4> const& elements) | Builds a mat4 from an array of four vec4 rows. src |
matrix_stack(vec4 const& row_1, vec4 const& row_2, vec4 const& row_3, vec4 const& row_4) | Builds a mat4 from its four rows (not columns). src |
matrix_stack(numarray_stack<float,16> const& elements) | Builds a mat4 from 16 values in row-major order. src |
matrix_stack(float xx, float xy, float xz, float xw, float yx, float yy, float yz, float yw, float zx, float zy, float zz, float zw, float wx, float wy, float wz, float ww) | Builds a mat4 from its 16 elements given row by row (xx, xy, xz, xw, yx, ..., ww), the translation being xw, yw, zw. src |
matrix_stack(mat3 const& M) | Builds the mat4 block matrix ((M, 0), (0, 1)) from a 3x3 linear part (explicit). src |
matrix_stack(matrix_stack<float,N1_arg,N2_arg> const& M) | Builds a mat2, mat3 or mat4 from a float matrix of another size (explicit), copying the common top-left block and setting the other elements to zero (a mat4 built from a mat3 uses the dedicated constructor instead, which puts 1 at (3,3)). src |
matrix_stack(float value) | Builds the mat2, mat3 or mat4 with the given value on the whole diagonal and zeros elsewhere (explicit, as in glm). src |
matrix_stack(float xx, float yy, float zz, float ww = 1.0f) | Builds a mat2 from its 4 elements given row by row (xx, xy, yx, yy). src |
matrix_stack(std::initializer_list<float> const& arg) | Builds a mat2, mat3 or mat4 from a brace list of floats; N*N or more values fill it in row-major order (extra ones ignored), 1 value or N values build a diagonal matrix (mat4 also accepts 3 values, with 1 as last diagonal element), and any other count raises an error. src |
matrix_stack(std::initializer_list<numarray_stack<float,4>> const& arg) | Builds a mat4 from a brace list of at least four vec4 rows (asserted); extra rows are ignored. src |
| Returns the identity matrix (ones on the main diagonal, zeros elsewhere; for a non-square generic matrix the diagonal has min(N1,N2) ones). src | |
| Returns a mat2, mat3 or mat4 with all elements equal to zero. src | |
| Returns a mat2, mat3 or mat4 with all elements equal to the given value. src | |
static mat4 build_diagonal(float value) | Returns the mat2, mat3 or mat4 with the given value on the whole diagonal (including element (3,3) of a mat4) and zeros elsewhere.3 overloads src |
static mat4 build_diagonal(vec4 const& arg) | Returns the diagonal mat4 whose diagonal is the given vec4. src |
static mat4 build_diagonal(float x, float y, float z, float w) | Returns the diagonal mat4 diag(x, y, z, w). src |
static mat4 build_scaling(float value) | Returns the uniform scaling matrix of the given factor; same as build_diagonal for mat2 and mat3, while a mat4 keeps 1 as element (3,3).3 overloads src |
static mat4 build_scaling(vec3 const& arg) | Returns the scaling matrix of factors (arg.x, arg.y, arg.z); for mat3 the diagonal matrix, for mat4 diag(arg.x, arg.y, arg.z, 1). src |
static mat4 build_scaling(float x, float y, float z) | Returns the scaling matrix of factors (x, y, z); for mat3 the diagonal matrix, for mat4 diag(x, y, z, 1). src |
| Returns the mat4 with linear part linear (top-left 3x3 block), translation tr (last column) and last row (0,0,0,1). src | |
static mat4 build_translation(vec3 const& tr) | Returns the mat4 of the translation tr (identity with tr in the last column).2 overloads src |
static mat4 build_translation(float x, float y, float z) | Returns the mat4 of the translation (x, y, z). src |
| Returns the mat4 ((M, 0), (0, 1)), same as the mat4(mat3) constructor. src | |
| Returns the matrix (mat3, or mat4 with zero translation) of the rotation of angle in radians around axis, normalized internally. src | |
| Returns the matrix (mat3, or mat4 with zero translation) of the rotation of a unit quaternion, whose norm is asserted to be within 0.05 of 1. src | |
| Sets the mat4 to the identity and returns a reference to it. src | |
| Sets all 16 elements of the mat4 to zero and returns a reference to it. src | |
mat4& set_diagonal(float value) | Replaces the mat4 by the diagonal matrix with the given value on its four diagonal elements and returns a reference to it.2 overloads src |
mat4& set_diagonal(float xx, float yy, float zz, float ww) | Replaces the mat4 by diag(xx, yy, zz, ww) and returns a reference to it. src |
| Overwrites the top-left 3x3 linear block with L, leaving the translation and the last row unchanged, and returns a reference to the mat4. src | |
mat4& set_block_linear_as_scaling(vec3 const& s) | Overwrites the top-left 3x3 block with diag(s.x, s.y, s.z), leaving the rest unchanged, and returns a reference to the mat4.3 overloads src |
mat4& set_block_linear_as_scaling(float sx, float sy, float sz) | Overwrites the top-left 3x3 block with diag(sx, sy, sz), leaving the rest unchanged, and returns a reference to the mat4. src |
mat4& set_block_linear_as_scaling(float s) | Overwrites the top-left 3x3 block with the uniform scaling diag(s, s, s), leaving the rest unchanged, and returns a reference to the mat4. src |
| Overwrites the top-left 3x3 block with the rotation of angle in radians around axis (normalized internally), leaving the rest unchanged, and returns a reference to the mat4. src | |
mat4& set_block_translation(vec3 const& tr) | Overwrites the translation part, elements (0,3), (1,3) and (2,3), with tr and returns a reference to the mat4.2 overloads src |
mat4& set_block_translation(float x, float y, float z) | Overwrites the translation part, elements (0,3), (1,3) and (2,3), with (x, y, z) and returns a reference to the mat4. src |
| Returns the translation part (m(0,3), m(1,3), m(2,3)) of the mat4 as a vec3. src | |
| Returns a copy of the top-left 3x3 block of the mat4 as a mat3. src | |
| Multiplies the top-left 3x3 block of the mat4 by s in place and returns a reference to it. src | |
| Multiplies the translation part (first three elements of the last column) by s in place and returns a reference to the mat4. src | |
| Multiplies the first three rows of the mat4 (linear block and translation) by s in place, leaving the last row unchanged, and returns a reference to it. src | |
| Adds xyz to the translation part of the mat4 in place and returns a reference to it. src | |
| Replaces the linear block L of the mat4 by T*L in place, leaving the translation unchanged, and returns a reference to it. src | |
| Returns the total number of elements N1*N2 (4, 9 and 16 for mat2, mat3 and mat4). src | |
| Returns the dimensions {N1, N2} (number of rows, number of columns) as an int2. src | |
| Sets every element to the given value and returns a reference to the matrix. src | |
| Returns a copy of the first column of the mat4 as a vec4. src | |
| Returns a copy of the second column of the mat4 as a vec4. src | |
| Returns a copy of the third column of the mat4 as a vec4. src | |
| Returns a copy of the fourth column of the mat4 as a vec4 (translation and 1 for an affine matrix). src | |
| Returns a const reference to the first row of the mat4 (a vec4). src | |
| Returns a const reference to the second row of the mat4 (a vec4). src | |
| Returns a const reference to the third row of the mat4 (a vec4). src | |
| Returns a const reference to the fourth row of the mat4 (a vec4). src | |
| Returns the first three elements of the first row of the mat4 as a vec3. src | |
| Returns the first three elements of the second row of the mat4 as a vec3. src | |
| Returns the first three elements of the third row of the mat4 as a vec3. src | |
| Returns the first three elements of the fourth row of the mat4 as a vec3. src | |
| Returns the first three elements of the first column of the mat4 as a vec3. src | |
| Returns the first three elements of the second column of the mat4 as a vec3. src | |
| Returns the first three elements of the third column of the mat4 as a vec3. src | |
| Returns the first three elements of the fourth column of the mat4, i.e. its translation part, as a vec3. src | |
| Returns a const reference to row k (a vec2, vec3 or vec4 for mat2, mat3 or mat4), with bound checking unless CGP_NO_DEBUG is defined. src | |
vec4 const& operator()(int k2) constvec4& operator()(int k2) | Returns a const reference to row k1 (a vector of N2 elements), with bound checking unless CGP_NO_DEBUG is defined.2 overloads src |
float const& operator()(int k1, int k2) constfloat& operator()(int k1, int k2) | Returns a const reference to the element at row k1 and column k2, with bound checking unless CGP_NO_DEBUG is defined. src |
| Returns a const reference to the element at the row-major offset k1*N2+k2; bound-checked for the generic matrix and mat4 (unless CGP_NO_DEBUG is defined) but not for mat2 and mat3. src | |
| Applies the mat4 to the point (p, 1) and returns the xyz part divided by w (perspective division, w is not checked against zero). src | |
| Applies the top-left 3x3 block of the mat4 to the vector v, ignoring the translation and the last row. src | |
| Returns the (N1-1)x(N2-1) matrix obtained by removing row k1 and column k2 (asserts k1<N1 and k2<N2), e.g. a mat2 for a mat3. src | |
| Copies a smaller matrix into this one with its top-left corner at (offset_1, offset_2), default (0,0), and returns a reference to this matrix; the block must fit (static_assert on its size, assert on the offsets). src | |
| Returns a const pointer to the first element (0,0) of the contiguous row-major storage. src | |
| Returns a const pointer one past the last element (N1-1,N2-1) of the contiguous row-major storage. src | |
| Returns a const pointer to the first element (0,0) of the contiguous row-major storage. src | |
| Returns a const pointer one past the last element (N1-1,N2-1) of the contiguous row-major storage. src | |
| Returns a const reference to the element at row k1 and column k2; bound-checked for mat2, mat3 and mat4 (unless CGP_NO_DEBUG is defined) but not for the generic matrix_stack. src | |
float const& coeff(int k1, int k2) constfloat& coeff(int k1, int k2) | Returns a const reference to the element at row k1 and column k2, without bound checking.2 overloads src |
vec4 const& coeff(int k1) constvec4& coeff(int k1) | Returns a const reference to row k1, without bound checking. src |
| Returns a const reference to the element at the given row-major offset, without bound checking. src | |
| Returns the inverse ((R^T, -R^T t), (0, 1)) of the mat4, assuming it is a rotation R followed by a translation t; the result is wrong if the linear block is not orthonormal, and the last row is ignored. src |
Functions taking a mat4
Transform 1
Compute 2
vec3 camera_ray_direction(
    mat4 const& camera_frame,
    mat4 const& perspective_inverse,
    vec2 const& screen_position
)
Unit world-space direction of the ray through a screen position given in normalized device coordinates [-1,1]^2, from the camera frame and the inverse projection matrix.
Convert 1
Other 1
Documented on another page
opengl_uniformSend a mat4 uniform (row-major, transposed on upload) to the shader; warns if the uniform is not found and expected is true.onopengl_shader_structure
Functions returning a mat4
Construct 5
mat4 projection_orthographic(
    float left,
    float right,
    float bottom,
    float top,
    float z_near,
    float z_far
)
OpenGL orthographic projection matrix mapping the box [left,right] x [bottom,top] x [-z_near,-z_far] to the unit cube.
mat4 projection_orthographic_inverse(
    float left,
    float right,
    float bottom,
    float top,
    float z_near,
    float z_far
)
Inverse of the orthographic projection matrix of projection_orthographic, computed in closed form.
mat4 projection_perspective(float fov, float aspect, float z_near, float z_far)OpenGL perspective projection matrix from a vertical field of view in radians, an aspect ratio (width/height) and the near and far distances.
mat4 projection_perspective_inverse(float fov, float aspect, float z_near, float z_far)Inverse of the perspective projection matrix of projection_perspective, computed in closed form.
mat4 tensor_product(vec4 const& a, vec4 const& b)Outer product a * transpose(b), as a 4x4 matrix.
Operators
Show the 18 operators (+, -, *, ==, ...)
operator*
5 overloadsmat4 operator*(mat4 const& a, mat4 const& b)Matrix product of two 4x4 matrices.
mat4 operator*(float s, mat4 const& M)4x4 matrix scaled by a scalar.
mat4 operator*(mat4 const& T1, affine const& T2)Product of a mat4 with the 4x4 matrix of the affine transform.
mat4 operator*(mat4 const& T1, affine_rt const& T2)Product of a mat4 with the 4x4 matrix of the rigid transform.
mat4 operator*(mat4 const& T1, affine_rts const& T2)Product of a mat4 with the 4x4 matrix of the transform.
operator*=
2 overloadsmat4& operator*=(mat4& a, mat4 const& b)Replaces a by the matrix product a*b.
mat4& operator*=(mat4& M, float s)Multiplies each coefficient of a 4x4 matrix by a scalar in place.
mat4& operator+=(mat4& a, mat4 const& b)Adds a 4x4 matrix coefficient-wise in place.