Inverse Kinematics
- IK: Inverse Kinematics
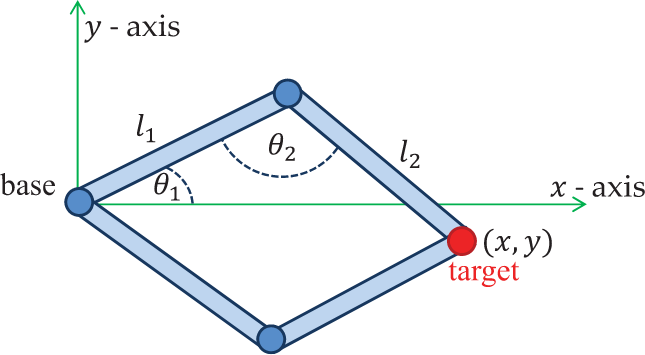
- - Describe position (/and orientation) of end-effectors (contact, walking, etc)
- - Compute joint angles reaching this position
\(\displaystyle p_k = p_0 + \sum_{i=0}^{k-1} l_i \;R_i\,u_i\)
\(R_i\) can be expressed with various rotation parameters (Matrices, Euler angles, axis/angle, quaternions, etc)
\(R_i\) can be expressed with various rotation parameters (Matrices, Euler angles, axis/angle, quaternions, etc)
MiloScerny Animation
10/41