Dual quaternion
- Idea: Use of dual quaternions
- Dual quaternion = Generalization of quaternion to dual number
-
- - \(\hat q = q_0 + \epsilon \, q_{\epsilon}\)
- - \(\epsilon\) : dual number \(\epsilon^2 = 0\)
-
- dual number commonly used to model infinitesimal quantity (ex. used for automatic differentiation)
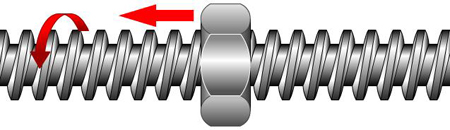
- A dual quaternion \(\hat q = q_0 + \epsilon \, q_{\epsilon}\) encodes a rigid transformation as a screw motion
-
- Screw motion: rotation about an axis followed by a translation in the direction of this axis
- - \(q_0\): pure rotation component
- - \(q_{\epsilon}\): encodes translation component (dual part)
34/41