Controlers
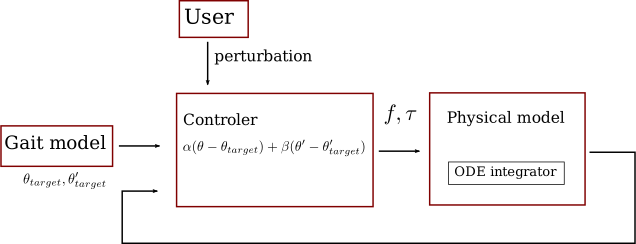
Mix between predefined motions and physics \(\rightarrow\) allow user perturbations
- Define target motions
- Use proportional derivative controlers (with feedback loop) to control forces and torques
-
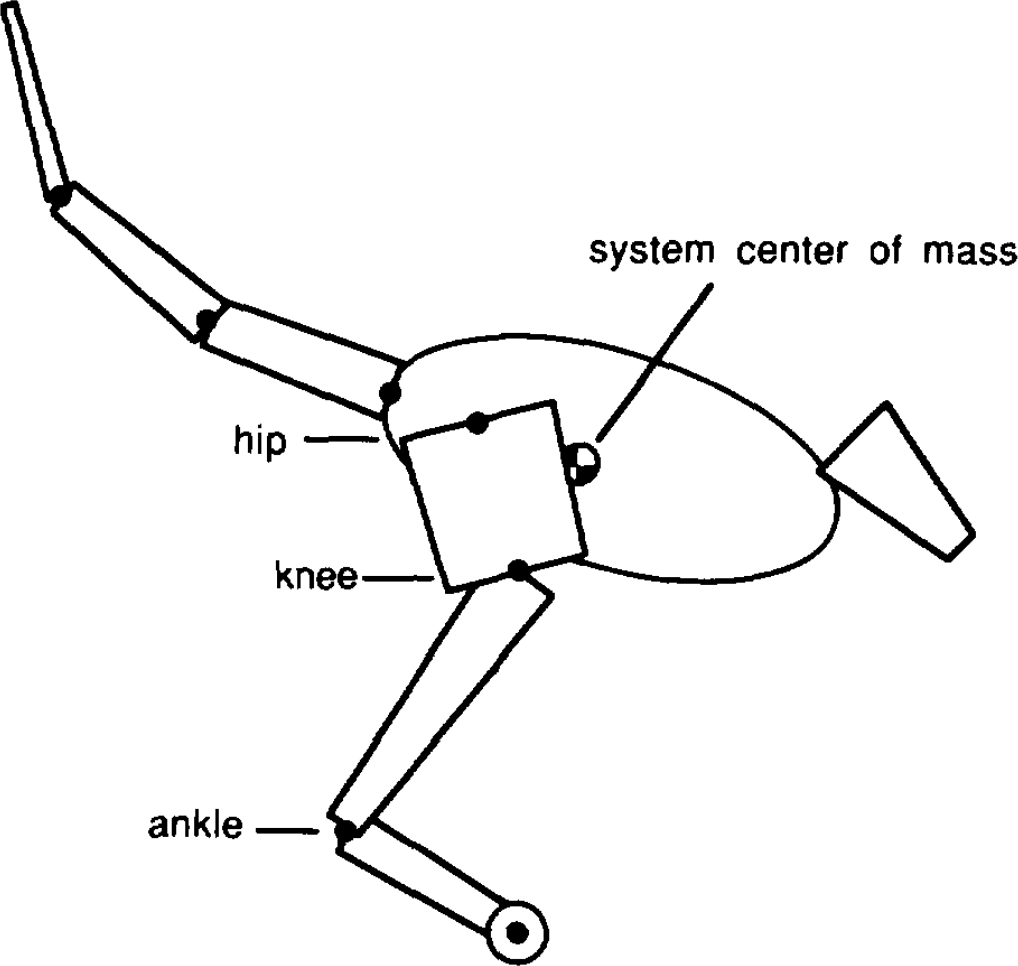
[M. Raibert and J. Hodgins. Animation of Dynamic Legged Locomotion, ACM SIGGRAPH 2001]
-
[K. Yin et al., SIMBICON: Simple Biped Locomotion Control, ACM SIGGRAPH 2007]
18/41
1 - Character Animation
2 - How to deform/animate character
3 - How to deform/animate character
4 - How to deform/animate character
5 - Character Animation
6 - Skeleton structure
7 - Encoding hierarchical skeleton
8 - Forward kinematics
9 - KF limits
10 - Inverse Kinematics
11 - IK Example with two bones
12 - Inverse Kinematics
13 - Inverse Kinematics
14 - Inverse Kinematics
15 - Inverse Kinematics
16 - Blending skeleton animation
17 - Motion graphs
18 - Controlers
19 - Motion transfert
20 - Animation design
21 - Skeletal animation and learning
22 - Character Animation
23 - Animating skin
24 - Brute force physically-based modeling
25 - Geometrical approach: Rigid Skinning
26 - Geometrical approach: Rigid Skinning
27 - Rigid skinning pro/cons
28 - Smooth skinning
29 - Smooth skinning - formulation
30 - Skinning Weights
31 - Linear Blend Skinning
32 - Improving LBS
33 - 1. Skinning Interpolation
34 - Dual quaternion
35 - Dual quaternion
36 - Dual Quaternion Skinning (DQS)
37 - Dual Quaternion VS LBS
38 - 2. Volume preserving skinning
39 - Geometrical constant volume skinning
40 - 3. Improving rigidity and avoiding self collision
41 - Implicit Skinning