mesh
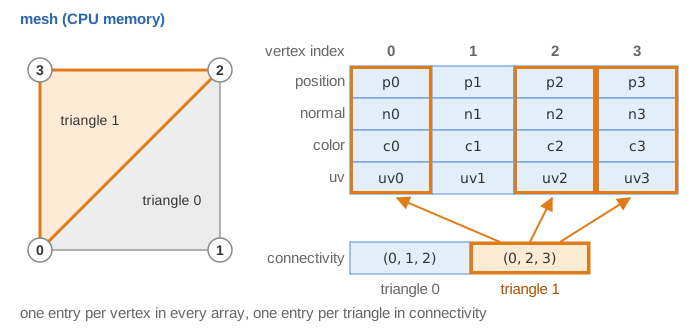
Triangle mesh stored on the CPU (positions, normals, colors, uv, connectivity).
Fields and methods
Members of the struct mesh. Most of what you do with a CGP type goes through the free functions listed below.
Fields
numarray<vec3> position | Per-vertex 3D positions of the mesh, indexed by the triangles of connectivity. |
numarray<vec3> normal | Per-vertex normals, expected to have the same size as position (filled by fill_empty_field or normal_update when empty). |
numarray<vec3> color | Per-vertex RGB colors in [0,1], set to white by fill_empty_field when missing. |
numarray<vec2> uv | Per-vertex texture coordinates, set to (0,0) by fill_empty_field when missing. |
numarray<uint3> connectivity | Triangles of the mesh, each given as a triplet of indices into the per-vertex arrays. |
Methods
| Fills the missing per-vertex fields (normals computed from the triangles, white colors, uv (0,0)) and returns the mesh. src | |
| Appends the vertices and triangles of another mesh, shifting its triangle indices by the current number of vertices, and returns the mesh. src | |
| Swaps the first two indices of every triangle to reverse its orientation, without modifying the stored normals, and returns the mesh. src | |
| Recomputes the per-vertex normals as the normalized sum of the unit normals of the adjacent non-degenerate triangles, and returns the mesh. src | |
mesh& translate(vec3 const& t) | Adds t to every position, leaving the normals unchanged, and returns the mesh.2 overloads src |
mesh& translate(float tx, float ty, float tz) | Adds the translation (tx,ty,tz) to every position, leaving the normals unchanged, and returns the mesh. src |
mesh& scale(float s) | Multiplies the positions by s about the origin (a negative s also flips the normals and the triangle orientation), and returns the mesh.2 overloads src |
mesh& scale(float sx, float sy, float sz) | Multiplies the x, y and z coordinates of every position by sx, sy and sz, recomputes the normals (reversing the triangles when sx*sy*sz < 0) and returns the mesh. src |
| Rotates the positions and normals by angle in radians around axis through the origin, and returns the mesh. src | |
mesh& apply_transform(mat3 const& M) | Multiplies every position by the 3x3 matrix M, recomputes the normals from the triangles with normal_update, and returns the mesh.5 overloads src |
mesh& apply_transform(mat4 const& M) | Applies the 4x4 matrix M to every position as a point, with the division by w, recomputes the normals with normal_update, and returns the mesh. src |
mesh& apply_transform(affine const& M) | Applies the affine transform to every position, maps each normal by the rotation and the inverse of scaling_xyz (negated for a negative scaling) before renormalizing it, reverses the triangles of a reflection, and returns the mesh. src |
mesh& apply_transform(affine_rt const& M) | Applies the rotation and translation to every position and the rotation to every normal, and returns the mesh. src |
mesh& apply_transform(affine_rts const& M) | Applies the rotation, translation and uniform scaling to every position and the rotation to every normal; a negative scaling also negates the normals and reverses the triangles; returns the mesh. src |
| Translates the positions so that the center of their bounding box is at the origin, and returns the mesh. src | |
| Scales the positions about the origin so that the largest side of the bounding box is 1 (call centered() first to fit a unit cube), and returns the mesh. src | |
| Writes the minimal and maximal corners of the axis-aligned bounding box of the positions in p_min and p_max (asserts that the mesh has a position). src |
Functions taking a mesh
Compute 1
bool mesh_check(mesh const& m)Check buffer sizes and triangle indices of a mesh, printing a warning for each problem found (including zero-length edges and unused vertices), and return false if a buffer or index is invalid.
Convert 2
std::string str(mesh const& m)Short summary of a mesh giving its number of vertices and triangles.
I/O 1
void mesh_save_file_obj(std::string const& filename, mesh const& m)Save a mesh as an .obj file with its positions, uv and normals (per-vertex colors are not stored).
Functions returning a mesh
Construct 14
mesh mesh_primitive_arrow(
    vec3 const& p0 = {0,0,0},
    vec3 const& p1 = {1,0,0},
    float cylinder_radius = 0.05f,
    float cone_height_scale = 4.0f,
    float cone_radius_scale = 2.5f,
    int N = 18
)
Arrow mesh from p0 to p1 made of a cylinder and a cone tip ending at p1, the cone length and radius being multiples of cylinder_radius (4 and 2.5 by default).
mesh mesh_primitive_cone(
    float radius = 0.5f,
    float height = 1.0f,
    vec3 const& center_of_base = {0,0,0},
    vec3 const& axis_direction = {0,0,1},
    bool is_closed_base = true,
    int Nu = 20,
    int Nv = 10
)
Cone mesh of base radius and height, with its base centered at center_of_base and pointing along the unit axis_direction, its base capped by a disc by default; Nu samples around the axis and Nv along the height.
mesh mesh_primitive_cube(vec3 const& center = {0,0,0}, float edge_length = 1.0f)Axis-aligned cube mesh of the given center and edge length, made of six independent two-triangle faces with flat normals.
mesh mesh_primitive_cubic_grid(
    vec3 const& p000 = {0,0,0},
    vec3 const& p100 = {1,0,0},
    vec3 const& p110 = {1,1,0},
    vec3 const& p010 = {0,1,0},
    vec3 const& p001 = {0,0,1},
    vec3 const& p101 = {1,0,1},
    vec3 const& p111 = {1,1,1},
    vec3 const& p011 = {0,1,1},
    int Nx = 10,
    int Ny = 10,
    int Nz = 10
)
Hexahedron mesh given by its eight corners, each of its six faces sampled as a regular grid (Nx, Ny, Nz samples along each direction).
mesh mesh_primitive_cylinder(
    float radius = 0.2f,
    vec3 const& p0 = {0,0,0},
    vec3 const& p1 = {0,0,1},
    int Nu = 10,
    int Nv = 20,
    bool is_closed = false
)
Cylinder mesh of the given radius around the axis [p0,p1], open by default or capped by two discs if is_closed is true, with normals and uv; Nu samples along the axis and Nv around it.
mesh mesh_primitive_disc(
    float radius = 1.0f,
    vec3 const& center = {0,0,0},
    vec3 const& normal = {0,0,1},
    int N = 40
)
Disc of the given radius centered at center and orthogonal to normal, made of N vertices on the circle linked to a central vertex, with a constant normal and uv mapping the disc into the unit square.
mesh mesh_primitive_ellipsoid(
    vec3 scale = vec3{1.0f, 1.0f, 1.0f},
    vec3 const& center = {0,0,0},
    int Nu = 40,
    int Nv = 20
)
Ellipsoid mesh with semi-axes scale.x, scale.y, scale.z centered at center, with normals and uv.
mesh mesh_primitive_frame(
    frame const& f = frame(),
    float scale = 1.0f,
    vec3 const& color_ux = {1,0,0},
    vec3 const& color_uy = {0,1,0},
    vec3 const& color_uz = {0,0,1},
    vec3 const& color_sphere = {1,1,1},
    float frame_thickness = 0.025f
)
Mesh of the frame f: three arrows of length scale along ux, uy and uz (red, green and blue by default) and a sphere at its origin, the arrow radius being frame_thickness*scale.
mesh mesh_primitive_grid(
    vec3 const& p00 = {0,0,0},
    vec3 const& p10 = {1,0,0},
    vec3 const& p11 = {1,1,0},
    vec3 const& p01 = {0,1,0},
    int Nu = 10,
    int Nv = 10
)
Bilinear patch through the four corners p00, p10, p11, p01, sampled as an Nu x Nv grid, with normals and uv; sample (ku,kv) has index kv + Nv*ku and uv (ku/(Nu-1), kv/(Nv-1)).
mesh mesh_primitive_quadrangle(
    vec3 const& p00 = {0,0,0},
    vec3 const& p10 = {1,0,0},
    vec3 const& p11 = {1,1,0},
    vec3 const& p01 = {0,1,0}
)
Quadrangle through the corners p00, p10, p11, p01, made of the triangles (p00,p10,p11) and (p00,p11,p01), with uv (0,0), (1,0), (1,1), (0,1) at the corners.
mesh mesh_primitive_sphere(
    float radius = 1.0f,
    vec3 const& center = {0,0,0},
    int Nu = 40,
    int Nv = 20
)
Sphere of the given radius and center sampled in spherical coordinates, Nu samples around the z axis and Nv from the south to the north pole, closed at the poles, with normals and uv.
mesh mesh_primitive_tetrahedron(
    vec3 const& p0 = {0,0,0},
    vec3 const& p1 = {1,0,0},
    vec3 const& p2 = {0,1,0},
    vec3 const& p3 = {0,0,1}
)
Tetrahedron mesh given by its four corners, made of four independent triangles with flat normals.
mesh mesh_primitive_torus(
    float r_max = 1.0f,
    float r_min = 0.25f,
    vec3 const& center = {0,0,0},
    vec3 const& axis_orientation = {0,0,1},
    int Nu = 55,
    int Nv = 15
)
Torus mesh of major radius r_max and minor radius r_min, centered at center around the unit axis axis_orientation, with normals and uv.
mesh mesh_primitive_triangle(
    vec3 const& p0 = {0,0,0},
    vec3 const& p1 = {1,0,0},
    vec3 const& p2 = {0,1,0}
)
Single-triangle mesh (p0,p1,p2) with a flat normal.
Compute 1
Documented on another page
marching_cubeExtracts the iso-surface of value iso of a field sampled on the grid domain (same dimension) as a new mesh whose triangles share their vertices, with normals computed by fill_empty_field.ongrid_3D
I/O 2
mesh mesh_load_file_obj(std::string const& filename)Load a single mesh from an .obj file, triangulating polygons and duplicating vertices where uv or normals differ (.mtl files are ignored).
Documented on another page
mesh_load_file_objLoad a mesh from an .obj file like mesh_load_file_obj, also returning for each file vertex the indices of the mesh vertices created from it (empty fields are not filled).onnumarray
Operators
None.